Abstract
Tactile sensing gives robots direct access to contact interactions, making it a key modality for robust and dexterous manipulation. Research in this area has evolved from mechanics-driven approaches that explicitly model contact to data-driven approaches that learn tactile representations and manipulation policies. Yet scaling these methods requires more than learning algorithms: it also requires a shared understanding of the manipulation skills robots need and reproducible tasks through which the community can study them.
In this talk, Professor Yuan will first present her lab’s work on mechanics-driven tactile manipulation, highlighting how tactile perception can inform manipulation actions across different contact scenarios. She will then discuss the challenges and opportunities in scaling data-driven approaches, motivating ContactBench, a benchmark we are developing for contact-rich robotic manipulation. Inspired by everyday objects and activities, ContactBench organizes the challenging contact-rich manipulation tasks into eight skill categories and pairs 3D-printable assets with simulation digital twins. It aims to provide a shared foundation for collecting data, evaluating methods, and understanding the intrinsic connection between system design and contact during manipulation.
Biography
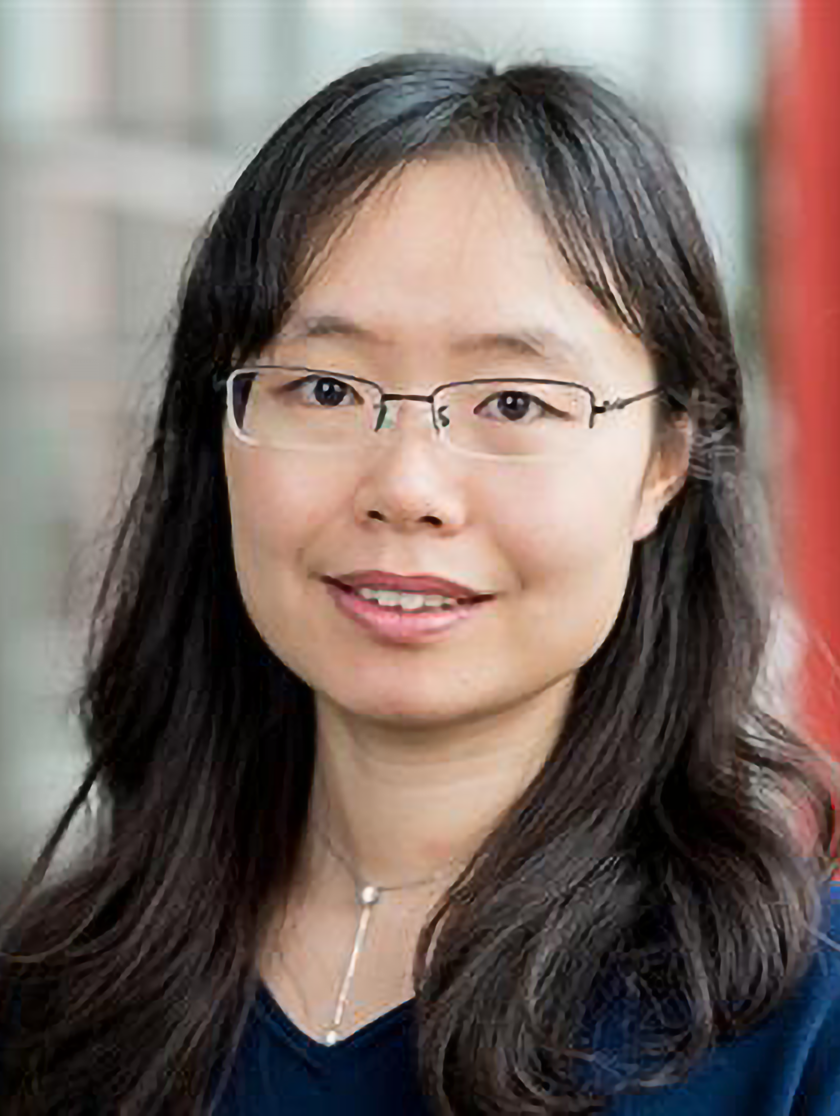
Wenzhen Yuan is an associate professor at the Siebel School of Computing and Data Science at the University of Illinois Urbana-Champaign and the director of the RoboTouch Lab. She is a pioneer in high-resolution tactile sensing for robots and also works in multimodal robot perception, soft robots, robot manipulation, and haptics. She is a recipient of the IEEE RAS Early Career Award and NSF CAREER Award. Her research has been acknowledged at an ICRA Keynote talk and early-career spotlight talks at RSS and CoRL.